Views: 0 Author: Site Editor Publish Time: 2026-08-31 Origin: Site
Industrial automation faces a critical performance bottleneck today. Modern robotics demand massive torque outputs inside highly constrained spaces. Traditional power transmission setups consistently fail these modern spatial requirements. Legacy gear systems quickly become a severe liability for overall equipment effectiveness. Excessive friction causes significant energy losses across the production line. Engineers struggle constantly against inertia mismatches during dynamic operations. Structural fatigue sets in rapidly during continuous heavy-duty cycles. You must re-evaluate your drivetrain components to maintain a competitive advantage.
We present a proven engineering path forward. You will discover how superior load distribution eliminates footprint limits entirely. We explore the internal mechanical interactions driving these dramatic efficiency gains. You will learn exactly how to match specific gearbox configurations to demanding industrial environments. Finally, we provide actionable steps for specifying the perfect precision components for your next major equipment upgrade.
Torque Density: Planetary systems distribute loads across multiple gears, allowing for higher torque transmission in a fraction of the space of parallel shaft designs.
Transmission Efficiency: Quality units routinely achieve 95% to 97% mechanical efficiency per stage, directly reducing motor power consumption.
Dynamic Response: Low inertia and high torsional rigidity make them ideal for rapid start-stop servo applications.
The concentric architecture represents a major leap in mechanical design. A central sun gear drives multiple planet gears simultaneously. These planet gears orbit inside a fixed outer ring gear. This arrangement distributes operational forces evenly across multiple contact points. You avoid concentrating extreme stress on a single fragile gear tooth.
Load sharing directly maximizes the power-to-weight ratio of the machine. Smaller internal components can safely transmit exceptionally high forces. You drastically reduce the overall mass of the entire drivetrain setup. Lighter components mean less energy wasted turning heavy metal parts. This weight reduction proves critical for high-speed automated systems moving rapidly along multi-axis tracks.
Energy transfer efficiency relies heavily on optimal contact mechanics. Traditional gearboxes suffer from excessive sliding friction between poorly optimized teeth. Sliding generates immense heat and wastes valuable motor power. Conversely, a Planetary Gear Reducer utilizes highly efficient rolling contact. Rolling minimizes heat generation during extremely heavy loads. High-quality units easily achieve mechanical efficiencies exceeding 95 percent per stage.
We see these mechanics shine in rigorous continuous operations. Engineers constantly battle against thermal limits and friction losses. The rolling concentric design fundamentally solves both issues. Your equipment runs much cooler. The attached servo motor requires significantly less electrical input power to perform identical work.
Engineers must carefully compare available drivetrain options during the design phase. Spur gears often serve basic power transmission needs adequately. They handle low-stress applications fairly well. However, spur designs rely entirely on single-tooth contact. All rotational stress hits one specific point at any given moment. This structural limitation severely restricts high-torque capacity. Spur systems also demand significant physical space to house larger diameter gears.
Worm gears present another traditional mechanical alternative. They provide very high reduction ratios inside tight right-angle spaces. Unfortunately, worm gears operate primarily on sliding friction. The steel worm heavily scrapes against the softer bronze wheel. This sliding action destroys transmission efficiency entirely. Most worm setups lose 50 to 70 percent of their input energy to heat. Planetary systems replace this wasteful sliding action using smooth rolling efficiency.
Below is a breakdown comparing these three common engineering technologies.
Drivetrain Alternatives Comparison Chart
Feature | Planetary System | Spur Gear | Worm Gear |
|---|---|---|---|
Efficiency per Stage | 95% - 97% | 85% - 90% | 30% - 50% |
Torque Density | Very High | Low | Medium |
Primary Contact Type | Rolling Multi-point | Rolling Single-point | Heavy Sliding |
Space Requirement | Highly Compact | Very Large | Compact (Right-angle only) |
You must deploy a logical decision matrix for optimal component selection. Avoid planetary setups for continuous, low-torque conveyor belts. Simple applications simply do not require premium concentric designs. Standard parallel-shaft gearboxes handle basic material transport tasks perfectly well. However, precise spatial positioning mandates a planetary architecture. High-speed robotics and automated packaging lines absolutely require this robust multi-point design.
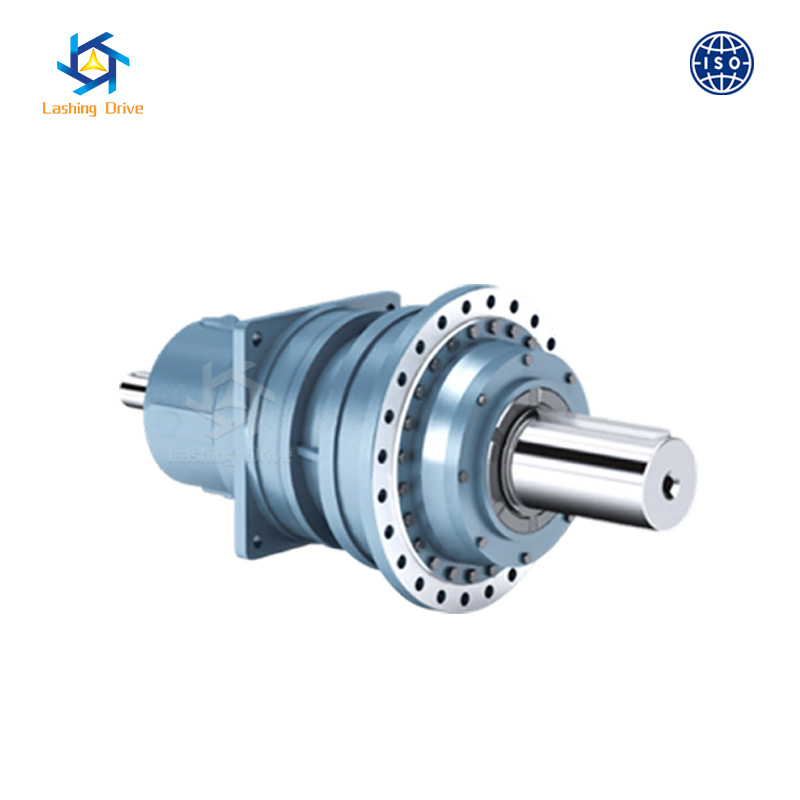
Physical space constraints dictate your final configuration choices. Direct coaxial alignments often demand an Inline Planetary Reducer. This straight-through design fits perfectly inside tight radial boundaries. Engineers heavily favor inline models for Automated Guided Vehicles (AGVs). Wheel drives in modern AGVs have strict width limits. Inline reducers drop right into the wheel hub assembly. Robotic arm joints also rely heavily on this narrow cylindrical profile.
Sometimes axial space proves more restrictive than radial space. Conveyor drives often bump directly against walkways or safety cages. Right-angle configurations solve this specific headache immediately. Manufacturers add a precision bevel gear stage to redirect the power 90 degrees. You will sacrifice a tiny percentage of efficiency here. The bevel gears introduce slight additional friction. However, the immense space-saving benefits usually outweigh this minor performance drop.
Modular integration simplifies the overall assembly process immensely. Modern equipment relies entirely on standardized mounting interfaces. A standardized Planetary Speed Reducer Gearbox features versatile motor flanges. You can seamlessly mount NEMA or IEC standard motors directly to the housing. You avoid custom engineering delays entirely. Maintenance teams appreciate how easily standard motors detach during servicing.
Scalability also improves drastically through modular staging. You can stack multiple gear stages together internally. This creates massive reduction ratios from standard off-the-shelf components. Your engineering team saves weeks of complex design time. Standardized components also ensure rapid emergency replacements during unplanned factory downtime events.
Modern servo motors require exact mechanical pairing to function properly. A bare servo motor cannot drive heavy loads directly in dynamic scenarios. The inertia mismatch causes severe control loop issues. The motor struggles constantly to start and stop the load smoothly. Position overshoot occurs frequently during rapid movement profiles.
A high-quality Precision Planetary Gear Reducer perfectly balances this physical inertia. The gearbox reduces the reflected load inertia by the square of the gear ratio. Your servo controller regains absolute command over the movement. Control loop tuning becomes straightforward and highly predictable. Ideal inertia ratios fall between 3:1 and 5:1 for highly dynamic automated tasks.
Positioning accuracy depends heavily on minimal internal backlash. Backlash represents the physical play between meshing gear teeth. High backlash ruins precision in any automated positioning task. CNC machines demand backlash levels well below 3 arc-minutes. Laser cutting beds require similar exactness to prevent jagged edges. Automated packaging lines fail entirely if timing drifts slightly. Precision models utilize ultra-tight manufacturing tolerances to eliminate this destructive mechanical play.
Torsional stiffness provides another crucial operational benefit. Sudden heavy loads cause inferior output shafts to twist slightly. This twisting phenomenon is commonly known as wind-up. Wind-up ruins repeatability during violent acceleration phases. Superior structural rigidity prevents this twisting entirely. Your machine hits the exact target coordinate every single time.
Even the best mechanical technology possesses distinct operational limits. The incredibly compact size inherently restricts natural heat dissipation. High rotational speeds generate significant thermal energy inside the closed housing. The small exterior surface area struggles to shed this heat quickly into the ambient air. Continuous duty cycles often push these thermal limits into dangerous territory.
You must monitor operating temperatures rigorously. Certain heavy-duty applications require active cooling systems. Liquid cooling jackets pull excess heat away from the housing efficiently. High-speed continuous operations usually mandate specialized synthetic lubricants. Synthetic oils resist thermal breakdown much better than standard mineral grease. Industrial duty cycles matter immensely here. A continuous S1 duty cycle generates constant heat. An intermittent S5 duty cycle allows vital cooling phases between movements.
Lubrication choices strictly dictate your long-term maintenance schedules. Many modern units arrive as "sealed-for-life" components. They contain high-grade synthetic grease applied precisely at the factory. You never need to open or lubricate them again under normal conditions. Conversely, extreme high-torque units often require deep oil baths. Oil-filled systems demand regular fluid changes and strict level checks.
Protective seals degrade rapidly in harsh industrial environments. Harsh chemical washdowns easily eat away at standard rubber compounds. Abrasive dust particles destroy rotating seal interfaces within months.
Common Mistakes to Avoid in Deployment:
Ignoring thermal saturation limits during continuous high-speed operational cycles.
Specifying heavy grease lubrication for high-temperature continuous running states.
Using standard protective seals in high-pressure chemical washdown environments.
Failing to align the motor shaft perfectly during initial physical installation.
Selecting the perfect unit requires methodical engineering calculation. You cannot simply guess the required torque values based on motor size. Successful specification relies entirely on accurate physical load profiling. You must clearly define three specific operational states.
Calculate the nominal running torque required during normal steady-state operation. Factor in friction from linear guides.
Determine the peak acceleration torque needed to start the massive load rapidly. You must know the exact time required to reach maximum speed.
Calculate the absolute emergency stop torque. E-stops generate massive shock loads capable of shearing undersized gears instantly.
Avoid the common engineering trap of over-specification. Engineers frequently request the tightest possible backlash class by default. They ask for 1 arc-minute ratings completely unnecessarily. Ultra-low backlash units require extreme manufacturing precision. A 5 arc-minute rating easily handles most standard automated packaging tasks. Match the specification strictly to your actual machine application tolerance.
Environmental ratings strictly dictate hardware survival rates. You must specify appropriate Ingress Protection (IP) ratings for the facility. Dusty environments require IP65 protection at an absolute minimum. Food and beverage facilities demand stringent IP69K ratings. High-pressure hot chemical washdowns quickly destroy standard painted housings. Select stainless steel bodies for highly corrosive atmospheres. Use specialized food-grade lubricants wherever product contamination risks exist.
Planetary configurations offer far more than basic rotational power transmission. They represent a highly strategic upgrade for system-wide mechanical efficiency. You gain unparalleled torque density inside incredibly tight machine footprints. Your attached servo motors achieve flawless inertia matching for rapid dynamic movements. You eliminate the massive electrical energy losses commonly associated with legacy worm gears.
Actionable next steps ensure successful component deployment. Start by mapping out your exact torque and speed profiles clearly. Review detailed technical spec sheets closely for thermal dissipation limits. Utilize manufacturer sizing calculators to verify your internal inertia matching. Finally, contact a specialized engineering team for a comprehensive factory drivetrain audit.
A: A high-quality single-stage unit typically achieves 95% to 97% mechanical efficiency. Adding a second stage drops overall efficiency slightly, usually landing around 90% to 93%. Internal energy loss comes primarily from rolling friction and necessary seal drag.
A: Yes, they are highly back-drivable due to their minimal internal friction. Unlike standard worm gears, they do not possess internal self-locking capabilities. You must install external mechanical brakes or rely on servo holding torque to secure vertical loads safely.
A: Inline models align the input and output shafts coaxially. This alignment creates a highly compact, cylindrical footprint. Parallel shaft gearboxes offset the internal shafts, requiring significantly more lateral space. Inline units also distribute torque across multiple internal gears simultaneously.
A: Severe radial overload on the output shaft bearings remains a leading cause. Improper motor installation causes internal misalignment, quickly destroying input bearings. Running continuous duty cycles without adequate cooling causes thermal breakdown of the internal protective lubricants.